| Navigation method | Fixed routes using magnetic tape, wires, reflectors, QR markers, or mapped paths | Map-based navigation using LiDAR, cameras, inertial sensors, and onboard software | AGV: stable, repetitive routes
AMR: changing routes and mixed traffic | Choose the navigation architecture that matches the expected frequency of layout and process changes. |
| Typical payload range | Approximately 100 kg to more than 10,000 kg, depending on vehicle design | Commonly approximately 100 kg to 1,500 kg; heavier platforms are available for selected applications | AGV: heavy, dedicated material movement
AMR: carts, totes, racks, and pallets | Specify payload as vehicle load plus container, fixture, and safety margin; do not size from product weight alone. |
| Route flexibility | Low to medium; route changes may require infrastructure or engineering work | High; vehicles can normally select alternative mapped paths around obstacles | AMR: facilities with frequent SKU, aisle, or workflow changes | Use AMR when operational flexibility has measurable value; use AGV when route stability supports maximum repeatability. |
| Floor and infrastructure requirements | May require guide paths, markers, reflectors, dedicated lanes, or floor modifications | Usually requires a surveyed map, reliable localization features, suitable lighting, and defined safety zones | AMR: existing facilities where civil work should be minimized | Audit floor flatness, slopes, thresholds, rack geometry, reflective surfaces, and pedestrian access before purchase. |
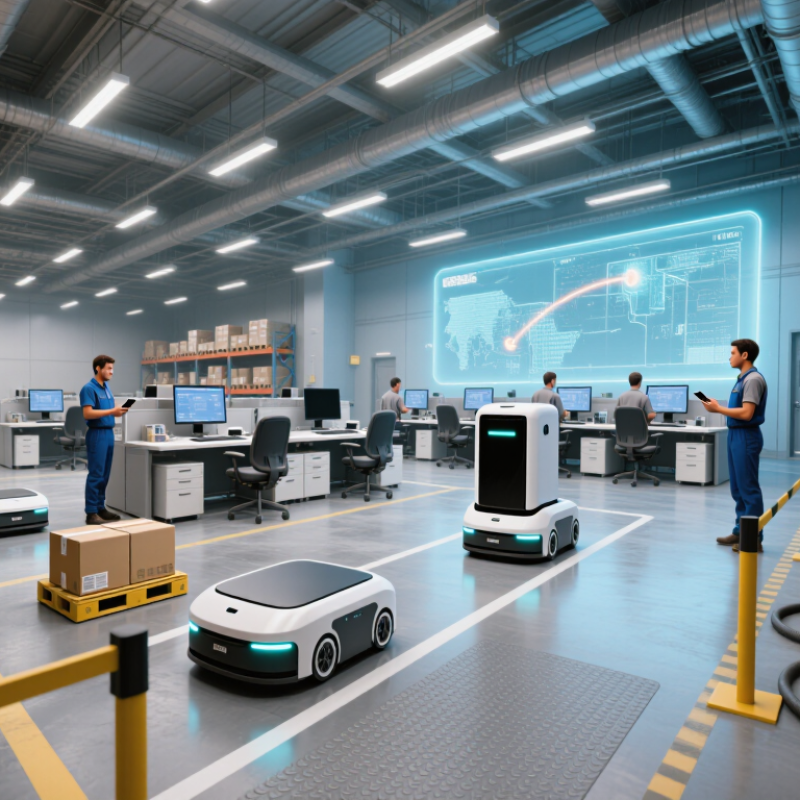
| Traffic and obstacle handling | Performs best in controlled lanes with predictable traffic and limited obstruction | Designed to detect obstacles, slow down, stop, and re-plan within defined operating limits | AMR: pedestrian-heavy or dynamically changing environments | Validate recovery behavior, not only detection. Confirm how the fleet handles blocked aisles, stalled vehicles, and lost localization. |
| Typical operating speed | Common industrial designs operate around 0.5–2.0 m/s, subject to load and safety limits | Common industrial designs operate around 0.8–2.0 m/s, with speed reduced in shared areas | Both can support routine intralogistics transport when cycle time is correctly modeled | Compare completed missions per hour, including loading, unloading, waiting, charging, and traffic delays. |
| Deployment timeline | Often longer when guide paths, controls, or dedicated lanes must be installed | Often faster for pilot deployment when maps and interfaces can be prepared without major construction | AMR: phased automation and rapid proof-of-concept programs | Require a documented pilot-to-production plan with acceptance tests, training, and change-control milestones. |
| Fleet management | Central control commonly coordinates routes, traffic priorities, charging, and station calls | Fleet manager commonly assigns missions, manages maps, controls traffic, and optimizes vehicle utilization | Both require centralized monitoring for multi-vehicle operations | Prioritize open APIs, clear event logs, role-based access, dashboard export, and support for mixed vehicle fleets. |
| System integration | PLC, conveyor, warehouse control, manufacturing execution, and warehouse management interfaces | Warehouse management, warehouse control, manufacturing execution, robot, elevator, door, and conveyor interfaces | Both suit structured digital workflows | Request interface documentation, simulator access, data ownership terms, and integration responsibility before contracting. |
| Charging approach | Opportunity charging or scheduled charging; battery chemistry and capacity vary by duty cycle | Opportunity charging, automatic docking, or battery exchange depending on fleet design | Both can support multi-shift operations with correct energy modeling | Model peak demand, charging dwell time, battery degradation, and spare-vehicle requirements over the full shift. |
| Safety framework | Risk assessment, protective scanners, emergency stops, warning devices, and controlled travel zones | Risk assessment, protective scanners, 3D or vision sensing, emergency stops, and dynamic speed control | Both require site-specific validation and worker training | Assess compliance with applicable machinery, mobile-robot, electrical, and workplace-safety requirements in the target region. |
| Maintenance requirements | Mechanical components, drive systems, guide infrastructure, batteries, sensors, and control equipment | Drive systems, batteries, sensors, computing hardware, maps, software, and network connectivity | AGV: infrastructure maintenance must be included
AMR: software and sensor maintenance must be included | Compare preventive-maintenance intervals, local service capability, spare-parts lead time, and remote-support coverage. |
| Scalability | Scales effectively on standardized, high-volume routes; capacity may require additional infrastructure | Scales flexibly by adding vehicles and adjusting software-defined workflows, subject to traffic capacity | AMR: variable demand; AGV: predictable high-volume transport | Test the fleet at projected peak volume, not average volume, and define the maximum supported vehicle count. |
| Best long-term KPI set | Mission completion rate, route availability, utilization, cycle time, charging availability, and maintenance cost | Mission completion rate, obstacle-recovery time, utilization, traffic delay, localization incidents, and maintenance cost | Both require operational, financial, safety, and service metrics | Set baseline values before deployment and review performance monthly against agreed service-level targets. |
| Total cost of ownership | Vehicle cost plus guide infrastructure, controls, installation, facility changes, energy, labor, and maintenance | Vehicle cost plus software, mapping, integration, network, energy, labor, and maintenance | The lower purchase price does not necessarily produce the lower lifecycle cost | Calculate five- to ten-year TCO using throughput, labor effects, downtime, expansion, support, batteries, and end-of-life assumptions. |
| Recommended decision rule | Select when routes are stable, traffic is structured, payloads are heavy, and throughput is predictable | Select when workflows, routes, demand, or facility conditions are expected to change | Hybrid deployment may be appropriate for sites with both fixed and flexible flows | Base the final choice on validated process data, safety results, integration readiness, and lifecycle economics. |


 08045479132
 Send Inquiry


 Send Inquiry
 Send SMS